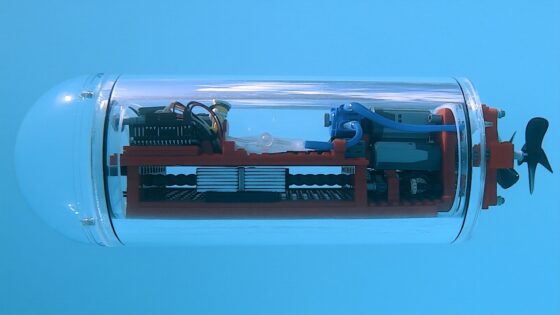
Improved radio-controlled submarine, with two new features: 1) a moving weight for changing pitch, and 2) a water pump based ballast system. Lots of minor improvements too. Equipped with an Arduino Nano ESP32, a pressure sensor and a gyro/accelerometer sensor. Tested in a swimming pool and a small river. Enjoy!
0:00 building
04:10 test in a swimming pool
04:46 test in a river
SPECS
Displacement: 2.95 kg
Test depth: 1.5 m
Hull: acrylic plastic cylinder (250x120x3mm)
Round nose: plastic half ball (12 cm diameter)
Extra weight: 1.35 kg of tungsten pellets
Pump: Kamoer NKP peristaltic pump modified with Lego parts
Ballast tank: 50 ml animal IV bag
Moving weight: 400g of steel washer plates
Propellers: non-Lego 4-blade 55mm diameter PC prop, L/R handed
Magnetic coupling: K&J Magnetics D36-N52 neodymium magnet
Motors: 3x Lego PF M-motor (8883), 1x Lego PF XL-motor (8882)
Motor driver: DRV8833
Radio control: Graupner R700 40MHz receiver, Graupner X-412 40MHz controller
Pressure sensor: Honeywell SSCMANV030PA2A3
IMU sensor: MPU-6050 6-Axis Accel/Gyro sensor
Computer: Arduino Nano ESP32
Power supply: Lego Rechargeable Battery Box 9V (8878)
On-board camera: GoPro 8
C++ CODE, PART LIST, AND OTHER DETAILS
PREVIOUS SUBS
1.0 syringe ballast
2.0 magnetic coupling
3.0 balloon and compressor
4.0 automatic depth control
Be the first to comment